Robot arms that hold still while you walk
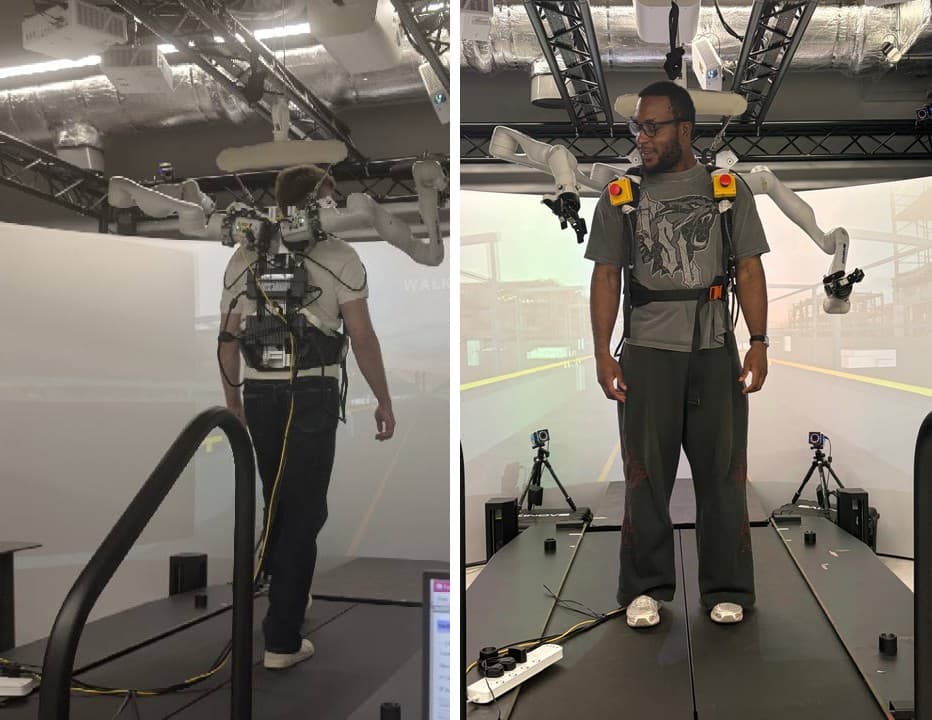
Wearable robot arms that try to keep their tools still in the room while the person wearing them walks.
- Year
- 2026
- Domain
- Robotics
- Role
- MSc thesis, control and experiments
- Stack
- C++, Python, MuJoCo, Vicon
The problem
An extra robot arm worn on your body is only useful if it can hold something steady. Every step you take moves the mount, so the arm has to cancel your motion rather than ride along with it.
What I built
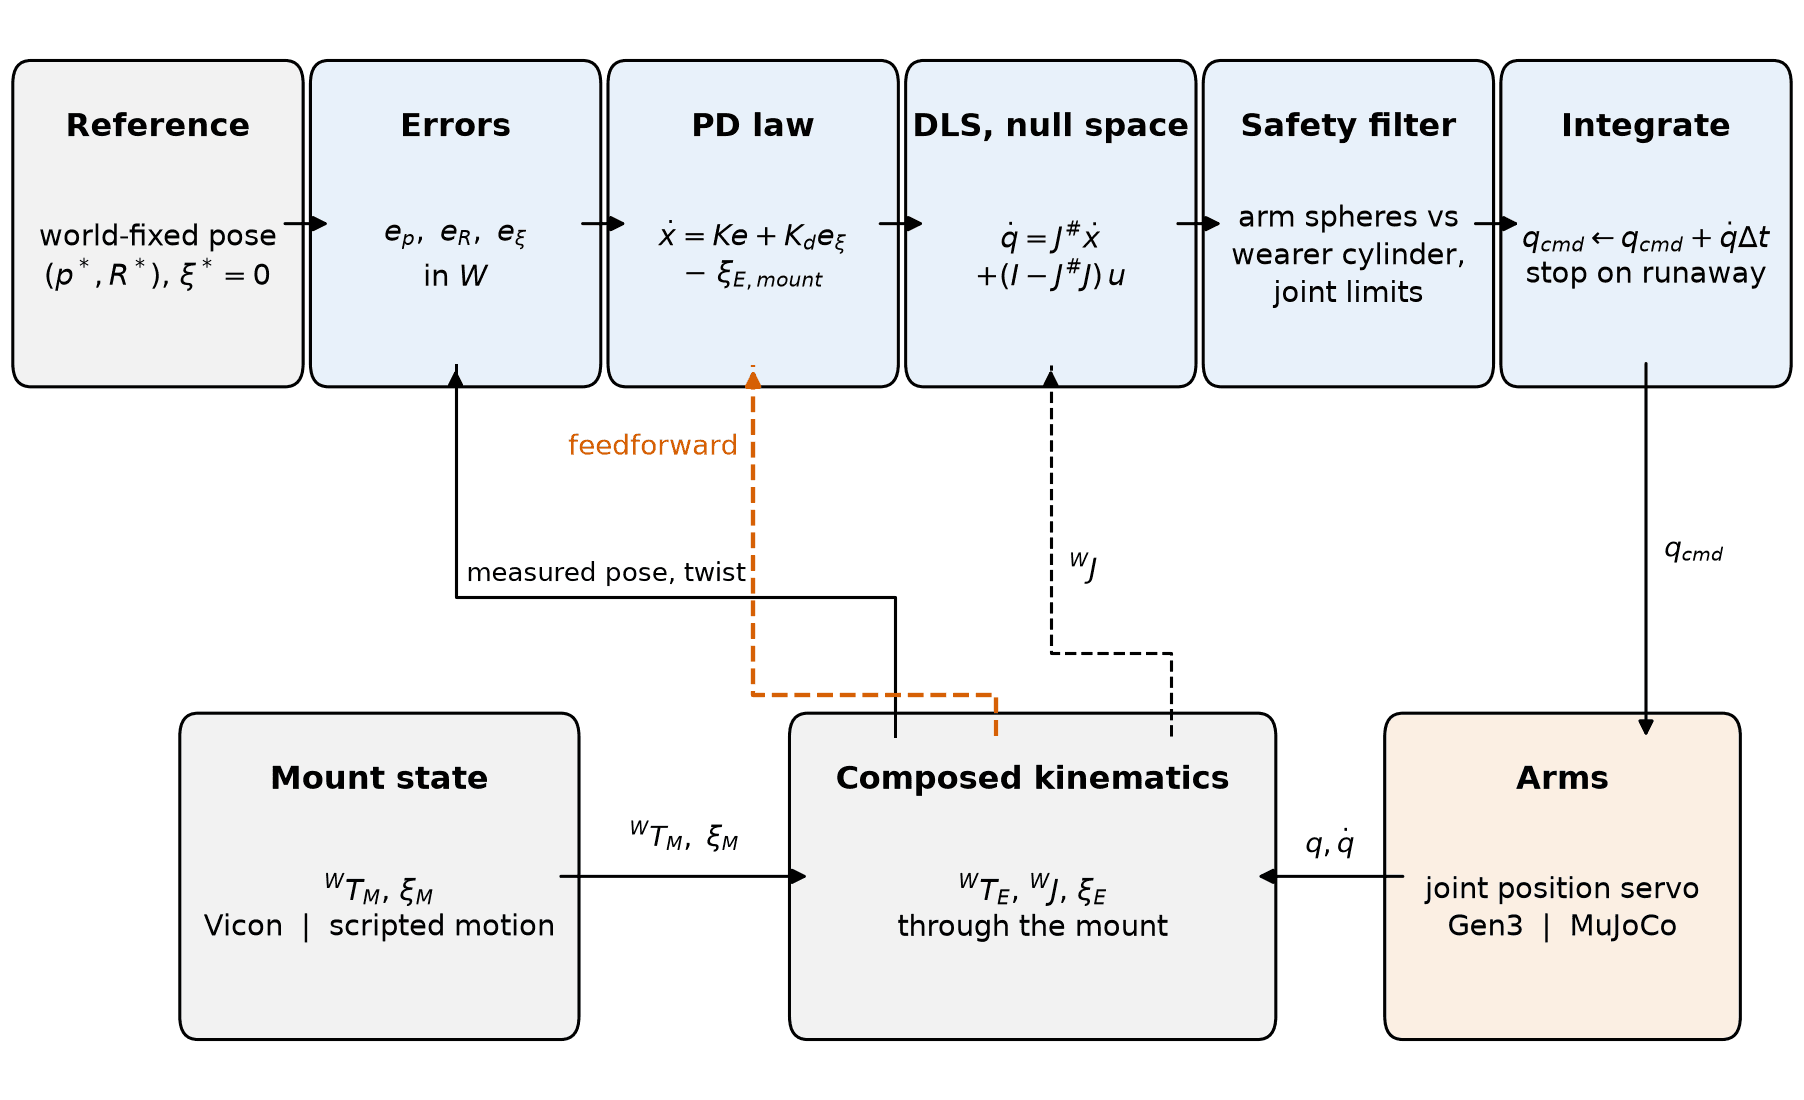
The controller that ran on two Kinova arms mounted on a backpack, with motion capture tracking the wearer, plus a simulation of the same system for testing ideas the hardware couldn't. Most of the work was the unglamorous part: frames, timing, joint limits and keeping the arms away from the person wearing them.
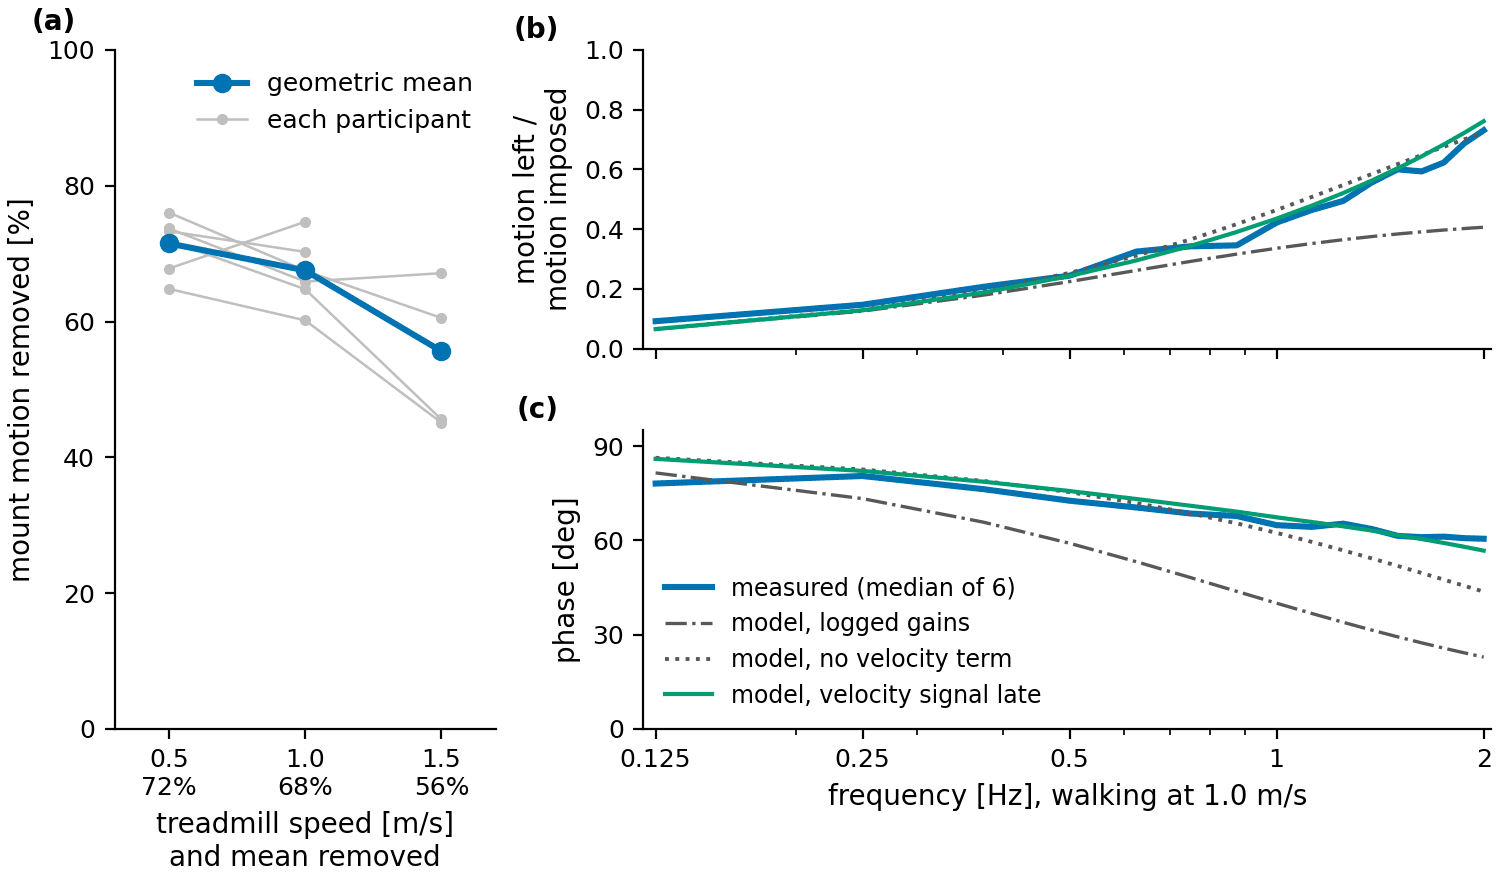
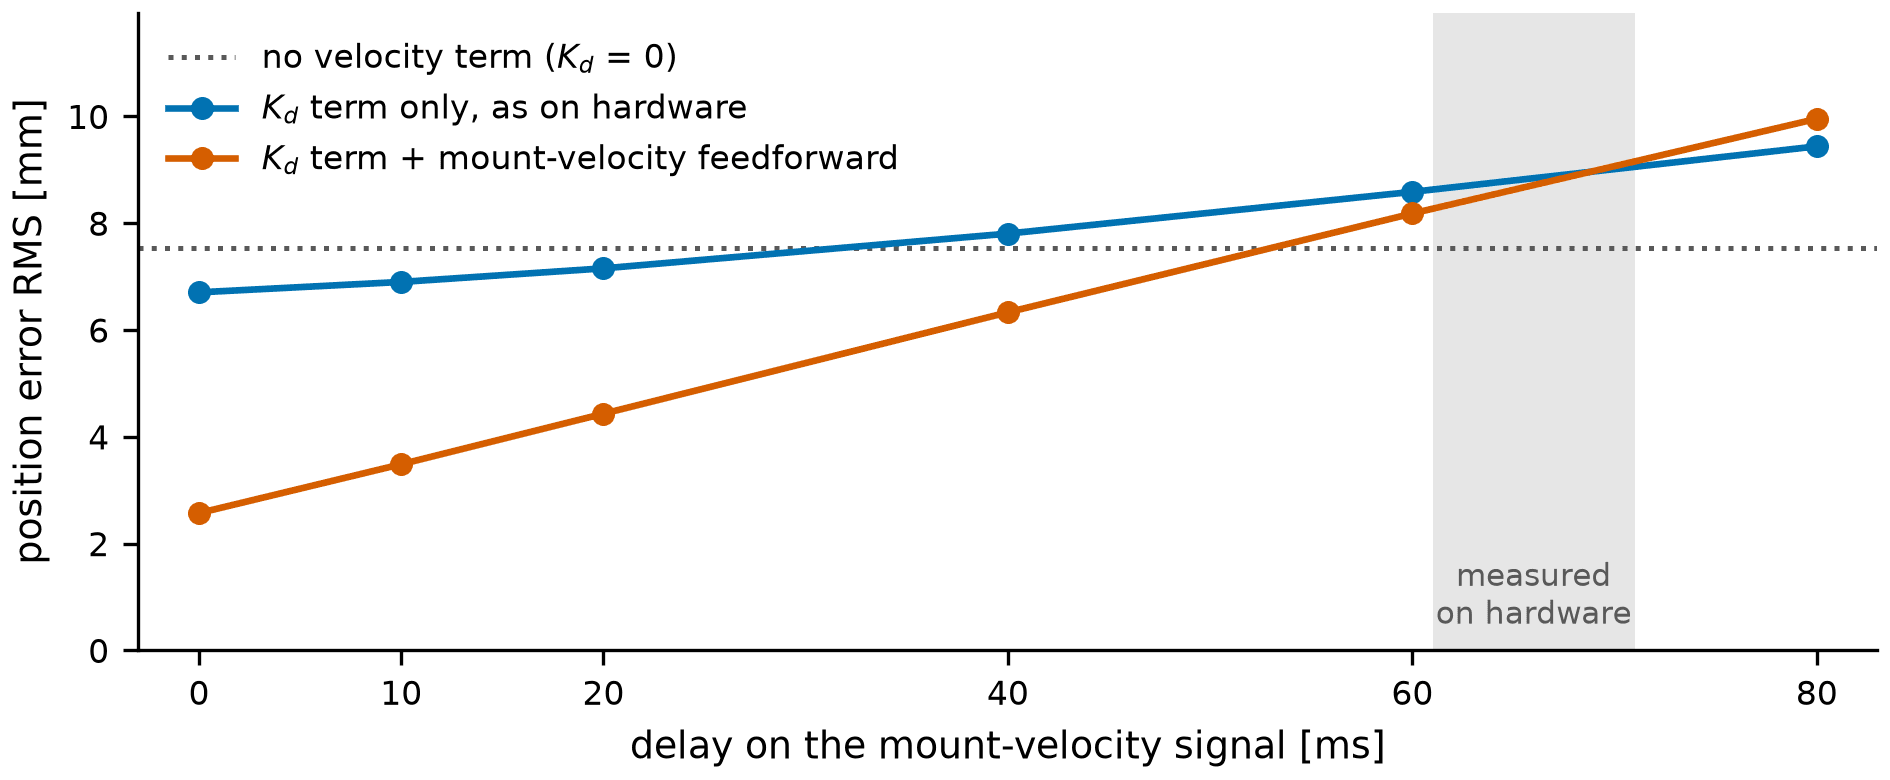
This is my MSc thesis and it is still being marked, so the results stay in the thesis for now. Happy to talk through them in person.
Figures